HumanFrame
Robotics built
around people.
A new humanoid platform for the places people already live, work and connect.
Humanoid platform in development · Product vision
Alp · In development
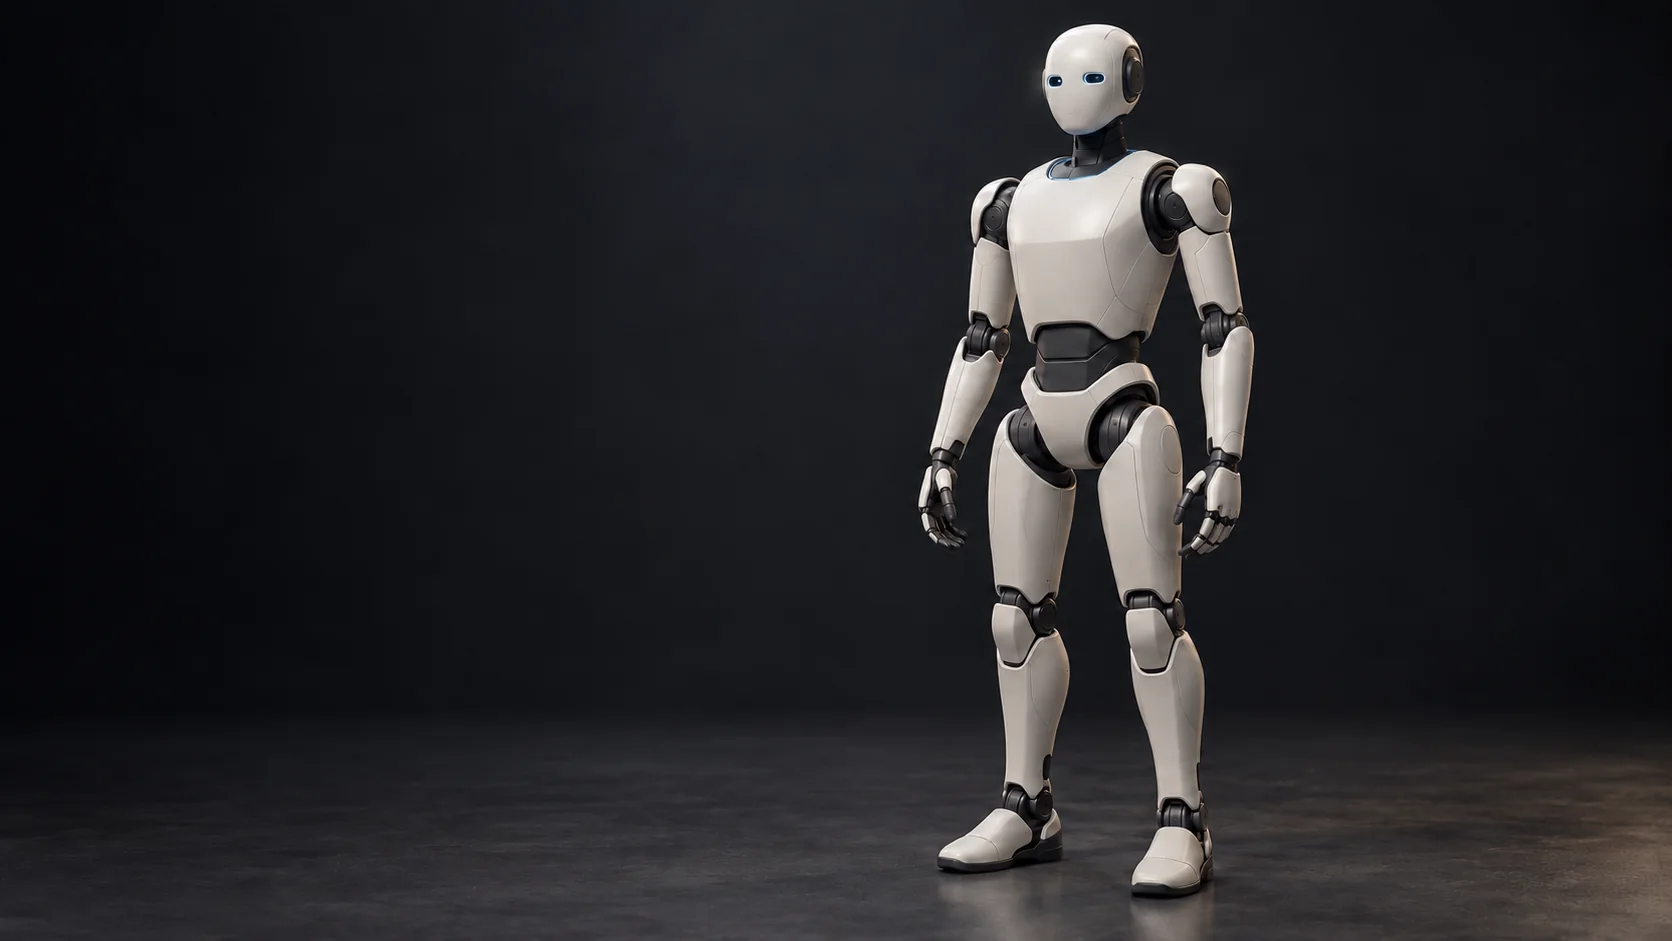
Meet Alp.
HumanFrame's humanoid robotic platform, designed around the spaces, interactions and proportions people already understand.


Interaction
Designed
to connect.
Attention can begin with something simple: a glance, a cue, a sense of presence. Alp explores expression through a minimal eye system and physical orientation.

Humanoid mobility
Built for a
human world.
Human environments are shaped around the way people move. Alp's intended bipedal form follows that same frame, from articulated hips to grounded feet.

Physical presence
Motion with purpose.
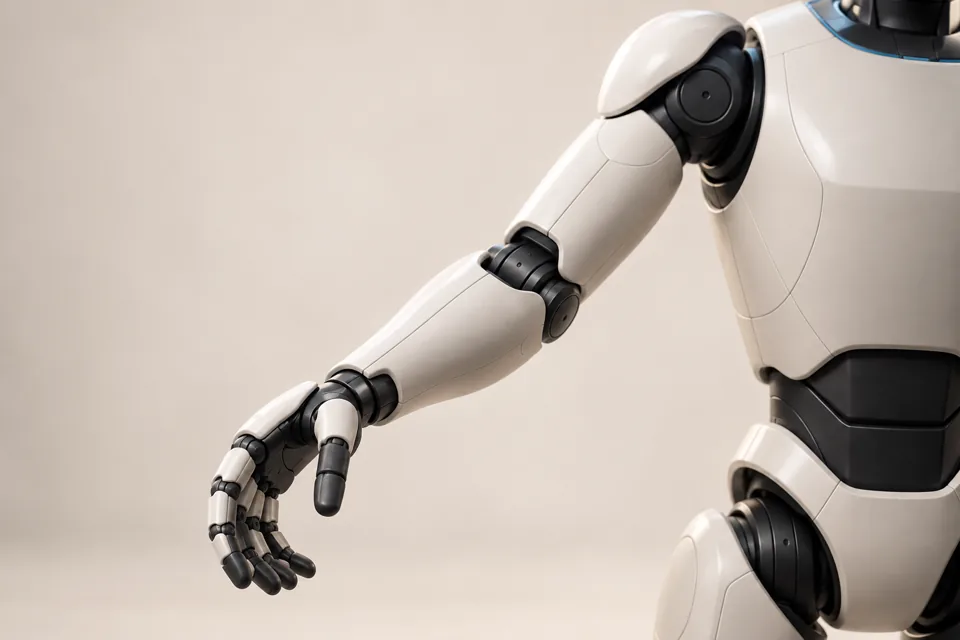
Arms, posture and orientation are part of the interaction. HumanFrame is developing an articulated platform whose movement can communicate as well as move.

Human environments
Built for
our world.
The world wasn't designed for robots. HumanFrame is designing robots around the world people already inhabit.
Context visualization · Alp in development
Engineering
Engineered from
the inside out.
Structure, actuation, compute and serviceable modules—developed as one system beneath the surface.

- Structure
- Joint systems
- Compute
- Serviceability
The HumanFrame system
Hardware is only
half the system.
- 01Alp
Humanoid hardware
- 02HumanFrame Software
Robot runtime and experience layer
- 03HumanFrame Platform
Applications, deployment and management
HumanFrame Platform
Software that moves
with the robot.
Build, deploy and evolve compatible applications across HumanFrame systems. The current Platform connects trusted Python web applications to local development machines and registered Linux robots.

Developers
Build on HumanFrame.
Create a compatible application, package it, select a target and follow the deployment from validation through health and logs.
- 01Create
- 02Package
- 03Upload
- 04Select robot
- 05Deploy
- 06Monitor
HumanFrame Robotics
Technology should
adapt to people.
We are building robotics around human environments, human interaction and human needs—not asking people to reshape their world around machines.